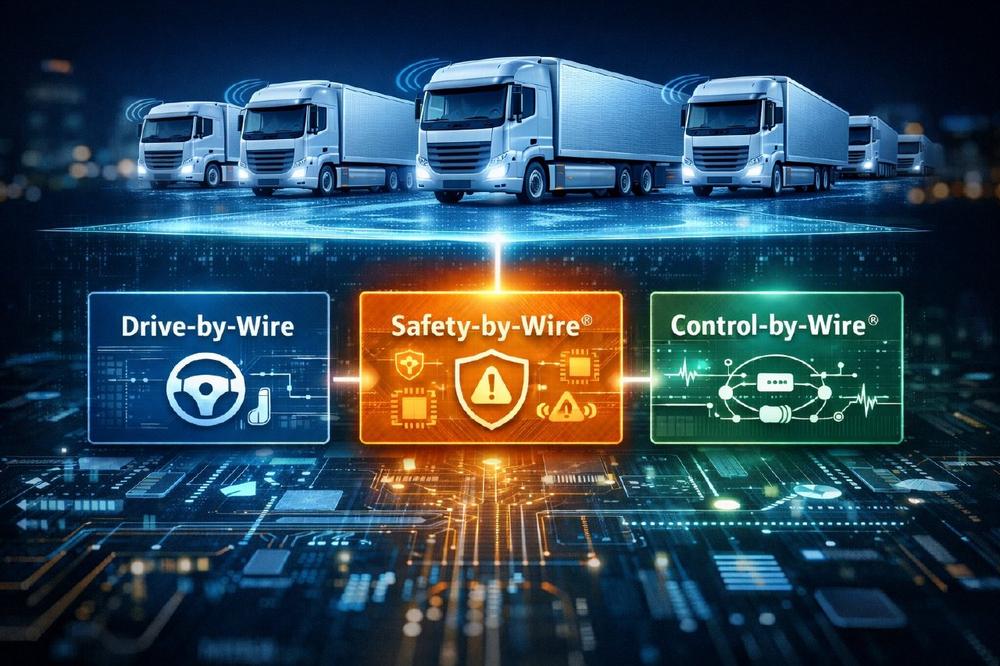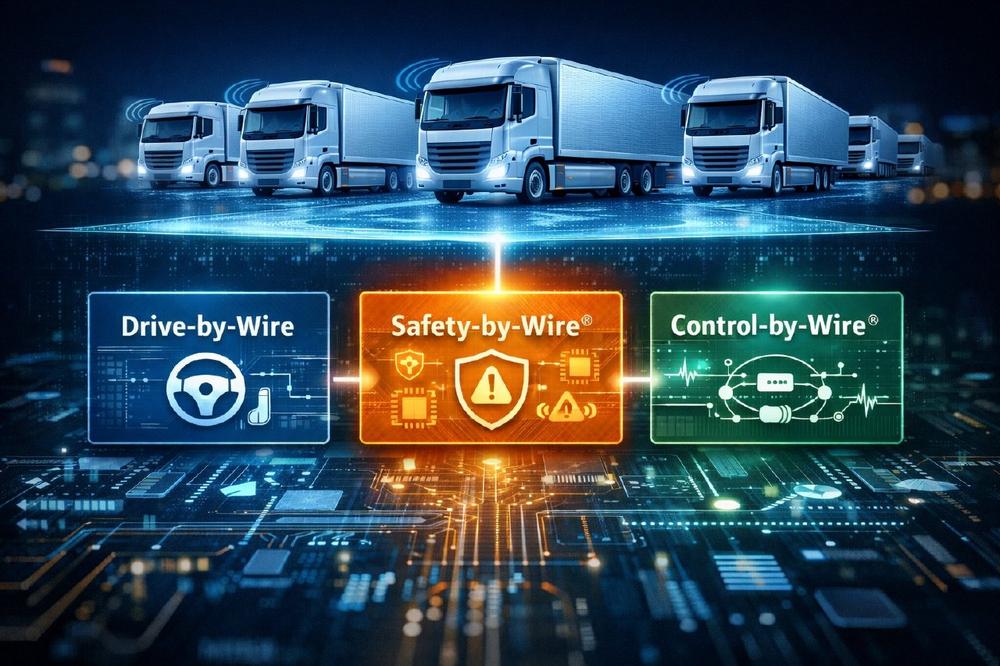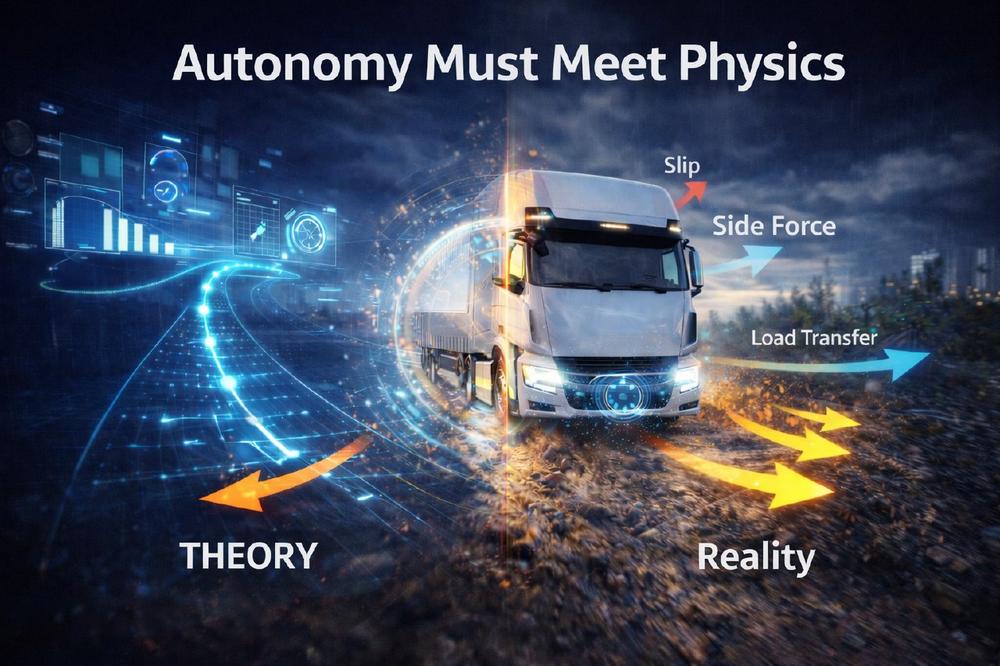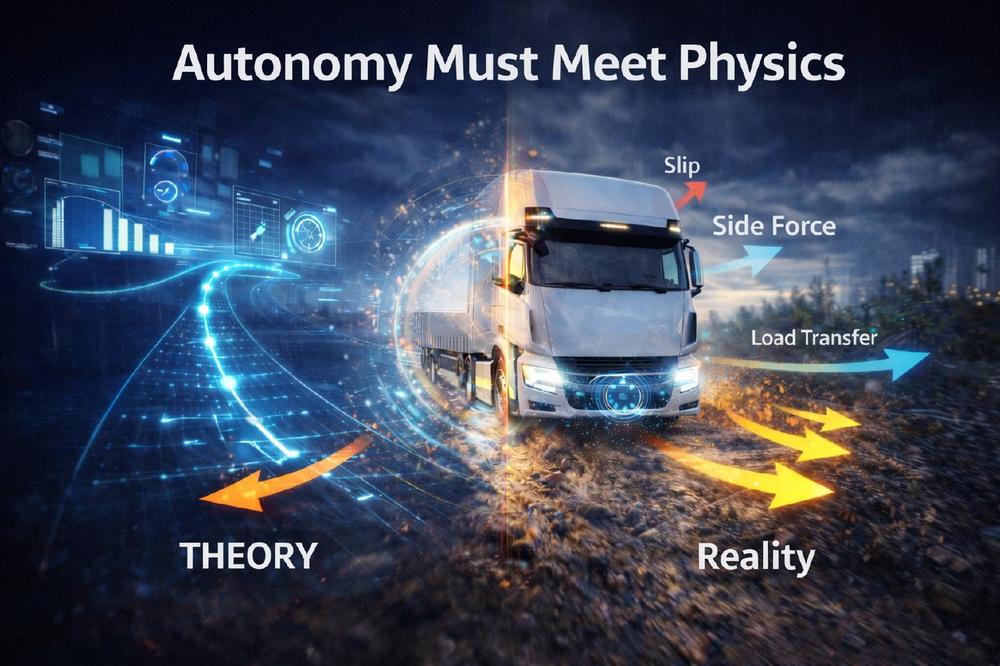
An autonomous commercial vehicle is on the road in daily operation. The route is known, the surroundings are mapped, and the sensors provide stable data. Then the situation changes: The road surface becomes uneven, a sensor reading deviates briefly, an actuator reacts with a delay. The vehicle recognizes the situation. The question is not whether […]
continue reading